Crew 328 Mission Summary

Report title: Mission Summary
Crew #: 328
Position: Commander / Crew Engineer / HSO
Report prepared by: Aaron Tenner
Date: 06-02-2026
Sol: 12

Summary:

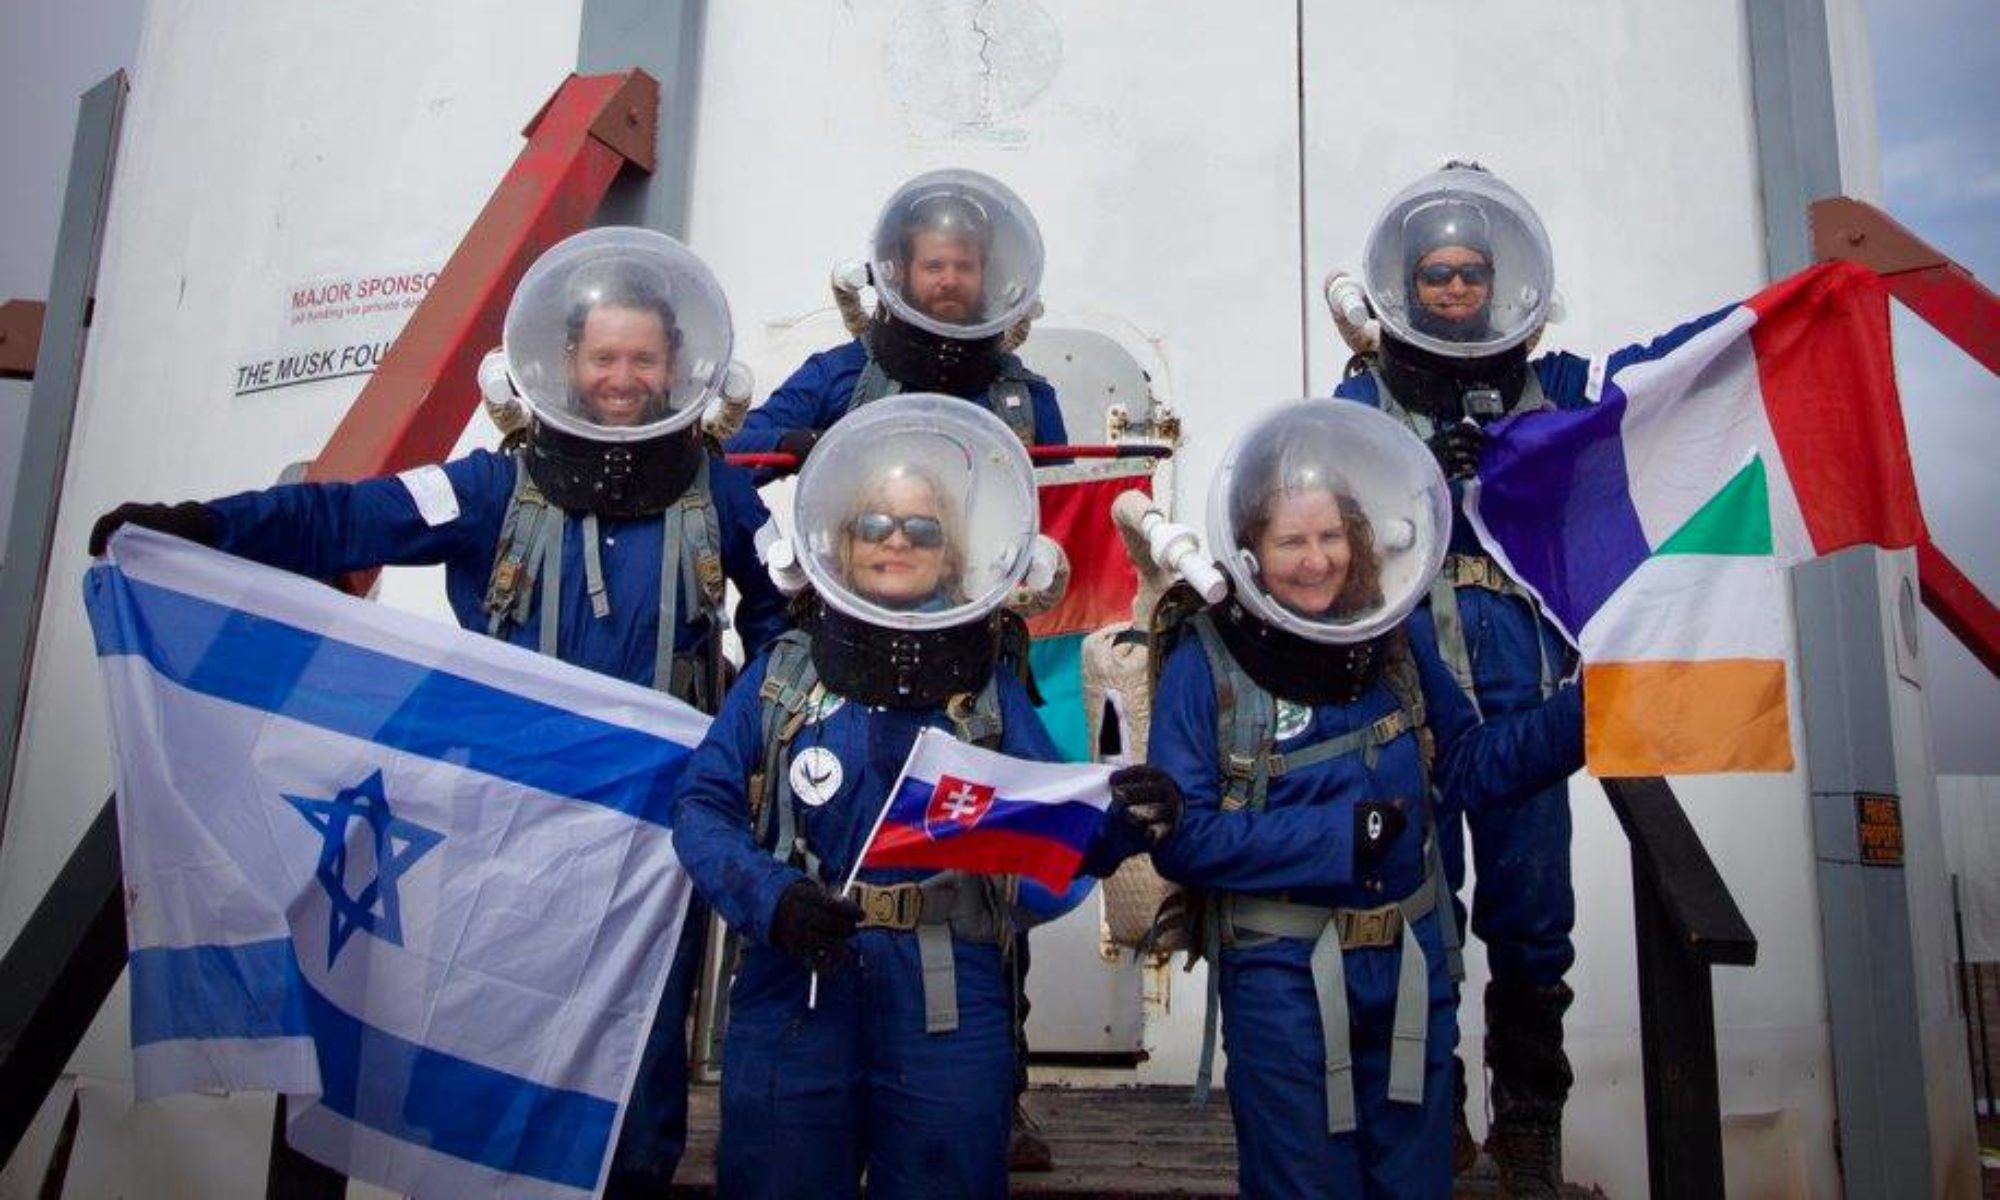
Crew 328 completed a successful 12-Sol simulation at the Mars Desert Research Station, operating under full Mars analog protocols. Our team of five brought diverse backgrounds and expertise to the mission, with strong cross-project collaboration and a shared commitment to science, safety, and outreach. The mission ran smoothly from arrival on Sol 0 through final handover on Sol 12, balancing intensive fieldwork, greenhouse experiments, materials testing, and a flagship delayed-comms outreach program that reached thousands of students worldwide. We conducted eleven EVAs that tested rover performance, radio procedures, and crew coordination under realistic constraints—including a tire puncture and comms blackout in a canyon—all resolved safely using established protocols. By the end, we left the Hab, GreenHab, Science Dome, and other modules cleaner, better organized, and fully inventoried, ensuring a stronger starting point for the next crew while advancing analog research and educational impact in meaningful ways.

Crew:

  • Commander: Aaron Tenner (Also Engineer & Health and Safety Officer)
  • GreenHab Officer: Rebeca Gonçalves
  • Crew Scientist: Jahnavi Dangeti
  • Crew Journalist: Tom Bickmore (Outreach & Communications focus)
  • Commander: Mariló Torres

Mission Objectives and Results:

GreenHab & Plant Experiments (led by Rebeca Gonçalves)

  • Tested growth of ISS-flown TomatoSphere seeds (H.J. Heinz Canada 1161F1, exposed during Expedition 70) in lab-simulated Martian regolith (with 10% organic amendment) and locally collected analog soil.
  • Ran radish microgreens comparison across four conditions: hydroponics, lab regolith, local regolith, and organic potting soil control.
  • Achieved radish germination on both MMS-2 Mars regolith simulant and local desert soil (collected from camel ridge), and achieved microgreen harvest on control organic soil and hydroponic setup.
  • ISS tomatoes and their Earth control counterparts are being handed over to the next crew.
  • Harvested fresh greens multiple times, boosting morale and demonstrating viable analog food production.

Soil & Materials Testing (led by Jahnavi Dangeti & Aaron Tenner & Tom Bickmore)

  • The work focuses on a materials science experiment examining the behavior of MDRS local soil under Mars-analogue habitat conditions.
  • Local soil was collected and sieved to standardize grain size, followed by testing multiple soil–water mixtures to identify a consistency suitable for reliable molding.
  • Baseline samples without additives were cast using small block molds and observed over several days under ambient habitat conditions, with qualitative documentation of drying behavior, cracking patterns, shrinkage, and shape retention.
  • Based on these baseline observations, the study is continuing with the evaluation of natural binders, such as guar gum, to assess their influence on early-stage soil consolidation under analogue conditions.
  • Tested structural performance and durability of hydroponics components printed in different filaments (e.g., PLA, PETG, ABS variants) under simulated Mars conditions.
  • Incorporated in-situ modifications using local Hab supplies to adapt designs for better integration with existing systems, improving reliability and printability for future analog or real Mars applications.
  • Collaborated with Jahnavi’s brick/regolith work to assess how printed parts might interface with or support soil-based experiments, yielding early insights into hybrid in-situ manufacturing.

Outreach & Comms Delay Experiments (led by Tom Bickmore)

  • Core project: Tested near-live video classes with ~10–20 min simulated Mars-Earth delay (constant bidirectional feeds, buffered for light-speed lag).
  • Ran multiple sessions: rehearsal with co-host students, main Outschool event (500+ families & classrooms, ~20 countries, ~1000 questions), plus The Launch Pad YouTube live-delay broadcast (over 2500 views so far).
  • Proved delay feels like genuine back-and-forth interaction (not pre-recorded clips); students on Earth ran Mission Control brilliantly. Survey results ongoing; outcomes potentially publishable.
  • Additional outreach: TV appearance (TeleCINCO Spain), school in India (Jahnavi’s former school), global classroom registrations doubled for final event, inspiring chat with Astronaut.

Topography & Photography (led by Tom Bickmore)

  • Configured high-res Mars topography model (Casey Handmer/Terraform Industries, 7 m/pixel 3D) on hard drive capable of live booting onto any personal laptop for future crews.
  • Captured sunrise/sunset timelapses, spotted Tiangong and ISS passes.

Operations & EVA Summary

  • Completed 11 EVAs (training, soil sampling, flag recovery, range testing, yard inspection, Sea of Shells exploration).
  • Key incidents: Tire puncture on Curiosity in canyon (handled via radio relay and 2-rover backup); rover range limit test (50% battery outbound).
  • Demonstrated strong radio procedures, EVA-Link tracking, rover safety, and teamwork under realistic constraints (no cell service, canyon blackout).
  • Final EVAs: Deep Sea of Shells walk (erosion stages, fossilized shells) and mountain overlook for Hab photos.

Hab & Station Handover

  • Deep cleaned Hab, GreenHab, RAM, and other modules.
  • Full inventory of consumables (food, supplies).
  • Minor repairs (chair legs, brackets, hinges).
  • Left all systems (smart home dashboard, EVA-Link, iMac, radios) in default state, ready for next crew.
  • Filed all required final reports.

Crew Reflections:

This mission succeeded through genuine collaboration across five countries and varied expertise. Projects intersected meaningfully (e.g., regolith from EVAs fed into brick and plant tests; outreach tied directly to science communication). We learned from each other constantly—personal strengths, cultural perspectives, and problem-solving approaches enriched the team. The delayed-video outreach proved not only technically feasible but emotionally impactful, connecting kids worldwide to analog Mars life.

Crew 328 leaves the station improved, experiments advanced, and a legacy of inspiration. Thank you to Mission Support, our families, and everyone who followed along. Mission complete.

Aaron Tenner, Commander, Crew 328
Sol Summary – January 1st

Report title: Sol Summary Report
Crew #: 326
Position: Crew Commander
Report prepared by: Keegan Chavez
Date: 01-01-2026
Sol: 4

Summary Title: New Year, Same Old Crew
Mission Status: all things nominal
Sol Activity Summary: Late start today after the New Years Eve festivities. Crew had their own meals throughout the morning before prepping for EVA 5. In the afternoon, disaster struck as we realized we were out of flour, and running low on salsa. Having hit a small snag in Katharina’s RF mapping project, a new procedure is being developed and will be tested on a shorter EVA on Sol 5. Crew spirits are staying high and research is starting to progress at a more rapid pace.
Look Ahead Plan: All EVAs have been planned, crew members are adapting their schedules with the knowledge of when they will be able to take their projects out on EVA
Anomalies in work: none
Weather: Cloudy throughout the day
Crew Physical Status: staying healthy and fit
EVA: Katharina, Idris, and Armand moved on foot to Skyline Ridge. The EVA team stopped at the top of Hab Ridge to begin testing the RF meters for Katharina’s sensor project. While running the RF signal generator from the Hab, CAPCOM is not able to receive a radio signal from the EVA team. This procedure was deemed too dangerous for operation and that aspect of the EVA was canceled. Idris was able to place an environmental sensor about halfway along the route to Skyline Ridge, and Armand was able to gather data for her project. The EVA team made it all the way to Skyline Ridge to gather images for the autonomous rover navigation project before returning to the Hab.
Reports to be filed:

Sol Summary

GreenHab Report

Operations Report

Journalist Report

Daily Photos

EVA Report

EVA Request x2

Support Requested: Bread is a large part of our calorie consumption so far and we have run out of all-purpose flour, we would like to request some more

GreenHab Report – January 1st

Report title: GreenHab Report
Crew #: 326
Position: GreenHab Officer
Report prepared by: Vindhya Ganti
Date: 1-1-2025
Sol: 4
Environmental control (fan & heater):
GH Fan Max: 80 degrees F
GH Fan Min 75 degrees F
Heating: 73 degrees F
Average temperatures (last 24h): 72.6 degree F
Maximum temperature (last 24h): 76.8 degrees F
Minimum temperature (last 24h): 68.4 degrees F
Hours of supplemental light:
ON: 18:00 OFF:20:00
Daily water usage for crops: 1 gallon
Daily water usage for research and/or other purposes: No
Water in the Tank (160 gal useful capacity): 153 gallons remaining
Time(s) of watering for crops: 11:30
Changes to crops: No changes
Narrative: Sprayed liqui-grow onto vegetables, misted microgreens, watered plants. Massed microgreens prior to watering for data collection. Harvested all medium to large lettuce leaves for addition to dinner.
Harvest: (include which crop and mass in grams) 10.25 grams of Lettuce harvested
Support/supplies needed: No supplies needed

EVA Report – January 1st

Report title: EVA Report
Crew #: 326
Position: Biologist
Report prepared by: Armand Destin
Date: 01-01-2026
Sol: 4

EVA #: 5
Purpose of EVA: Take readings at Hab Ridge and placement of environmental sensors at Skyline Rim for research.
Start time: 12:00
End time: 16:00
Narrative: Traveled to Hab ridge’s repeater to take radio readings. The radio readings experienced technical difficulties and testing will continue after the EVA. Continued north on Hab Ridge and the west on Sagan Street. Midway on Sagan Street the team placed environmental sensors near the path. The team continued to Skyline Rim and then returned to the Hab.
Destination per MDRS Map: Skyline Rim
Destination Coordinates (use UTM WGS 84): (N4251500 – 4251000), (E515000, E515500)
EVA Participants: Armand Destin (Crew Biologist), Idris Stevenson (Crew Engineer), Katharina Guth (Health and Safety Officer)
Road(s) and routes per MDRS Map: Follow footpath 1103 north from the Hab to Hab Ridge Road. Then follow the path west on Sagan Street 1103 to Skyline Rim.
Mode of travel: Walking

Operations Report – January 1st

Report title: Operations Report
Crew #: 326
Position: Crew Engineer
Report prepared by: Iris Stevenson
Date: 01-01-2026
Sol: 4

Non-nominal systems:
Notes on non-nominal systems:
ROVERS
Spirit rover used: NONFUNCTIONAL
Hours:
Beginning charge:
Ending charge:
Currently charging:
Opportunity rover used: Not used
Hours:
Beginning charge:
Ending charge:
Currently charging: No
Curiosity rover used: Not used
Hours:
Beginning charge:
Ending charge:
Currently charging: No
Perseverance rover used: Not used
Hours:
Beginning charge:
Ending charge:
Currently charging: No
General notes on rovers:

Summary of Hab operations:
Water Use: 23.46 gal
Main tank level: 317.4 gal
Main water tank pipe heater: ON
Main water tank heater: ON
Toilet tank emptied: NO
Summary of internet: Nominal
Summary of suits and radios:

  • Minor issues on channel 1 with one radio during EVA

Summary of GreenHab operations:
Water use: 1 gallon
Heater: ON
Supplemental light: 4 hours
Harvest: lettuce, 10.25g
Summary of ScienceDome operations:

  • Crew Scientist tested the bricks he made for his research project using his own tools

Dual split: Automatic
Summary of RAM operations: None
Summary of any observatory issues:
Summary of health and safety issues:
Questions, concerns and requests to Mission Support:

  • Request for rovers Curiosity, Perseverance, and Opportunity to be plugged in in preparation for Sol 5 EVAs

Journalist Report – December 31st

Report title: Journalist Report

Crew #: 326
Position: Crew Journalist
Report prepared by: Daria Bardus
Date: 31-12-2025
Sol: 3

Journalist Report Title: New Years Eve

This morning, we woke up to the smell of French toast and coffee before starting our day. Today, Idris, Katharina, and Vindhya had an early EVA, so they all had time to work on their respective research out in the field. They took the rovers to Kissing Camel Ridge before climbing up so Idris could place her sensors. Once they climbed back down, they headed north so Vindhya could take photos of Kissing Camel Ridge for her identification system. Once they had completed all their tasks, they came back to the hab and took off all their gear before heading up to help finish the puzzle Keegan started.

We had all originally planned to eat lunch around this time, however we all got so invested in the puzzle we decided to wait. Eventually we got to a point where the puzzle was almost done that we took a break to get leftovers and make sandwiches for lunch with some questionable whole wheat bread. However, when finishing the puzzle we ran into a problem: there were multiple pieces missing. Thanks to Keegan and Katharina, though, the last pieces were found in the cabinet and we were able to finish the puzzle. After that we played a long game of BS before eventually parting ways to rest a bit before the busy night. During this time, I worked on making cinnamon raisin bread and a cake to ring in the new year.

While those were baking, Ben and I headed to the science dome to work on forming his bricks from the soil sample he collected yesterday. The rest of the night involves us working on our research projects, playing games, and celebrating the new year!

Crew Photos – December 31st

Report title: Photos of the Day
Crew #: 326
Position: Crew Journalist
Report prepared by: Daria Bardus
Date: 31-12-2025
Sol: 3

Journalist Report – January 3rd

Report title: Journalist Report
Crew #: 326
Position: Crew Journalist
Report prepared by: Daria Bardus
Date: 01-03-2026
Sol: 6

Journalist Report Title: More Terraforming Mars

Today we woke up to foggy and cloudy weather which meant our EVA schedule was going to change. We had determined that the first EVA of the day was going to be cancelled and the second one would happen as planned. Until the EVA in the afternoon, we cleaned up the hab, read, worked on our projects, and then got Terraforming Mars out again. We played this until Ben and I had to go work on our projects. Once Ben had finished the next step of his brick making process and I had finished preparing the rover, we ate lunch. After lunch Keegan, Vindhya, and I got geared up for EVA. While out on EVA, Keegan placed two of Idris’ sensors around the hab and Vindhya and I found a spot to test the rover. While testing the rover, we found that testing on an inclined surface was more complicated than thought. This is because we would have to adjust the linear actuator as we went, so we went ahead and looked for flat areas to test. We ended up testing by the RAM, on the path towards the road, and near the science dome. We were able to collect samples and will collect data on them tomorrow.

While we were out on EVA, Ben and Idris worked on Ben’s research. Using the sample Ben collected on Hab Ridge, they formed more bricks to then be put in the oven. Once I had returned from EVA, I also put my samples in the oven with Ben’s formed bricks.

Once we were all done with working on our research for the time being, we finished our game of Terraforming Mars. In this last game Keegan won again but only by one point this time. We then began preparing dinner where we are going to have bean burgers with barbeque sauce and potato chips. After dinner we will clean up, work on our research projects, and play some more Murdle before heading to bed.

EVA Report – January 3rd

Report title: EVA Report
Crew #: 326
Position: Biologist
Report prepared by: Armand Destin
Date: 03-01-2026
Sol: 6
EVA #: 8
Purpose of EVA: Testing of Rover claw and navigation systems.
Start time: 15:00
End time: 17:00
Narrative: The team conducted testing of the rover outside the Hab. Testing of the rover was successful. The team placed sensors on the hill near the door of the Hab. Lastly photos were taken and the team returned to the Hab.
Destination per MDRS Map: Main Hab
Destination Coordinates (use UTM WGS 84): N4251000, E518250
EVA Participants: Keegan Chavez (Crew Commander), Vindhya Ganti (GreenHab Officer), Daria Bardus (Crew Journalist)
Road(s) and routes per MDRS Map: This will be taking place right outside the main Hab, between the Hab and the state road.
Mode of travel: Walking